Stabilization, Station Keeping and Tracking
-
Spin stabilization: The body spins to give gyroscopic (angular-momentum) stiffness; a bearing and motor keep a despun antenna platform Earth-pointing.
-
Three-axis stabilization: Attitude sensors, a controller and orthogonal reaction/momentum wheels control roll, pitch and yaw; thrusters give coarse correction and unload accumulated wheel momentum.
-
Station keeping: North–south and east–west thruster burns hold the assigned orbital slot against perturbations.
-
Ground tracking: A closed loop turns beacon pointing error into azimuth/elevation motor commands, with encoder feedback closing the servo loop.
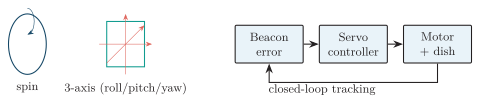
Spin versus three-axis stabilization and the closed-loop az/el tracking servo.